题目
Problem
8.
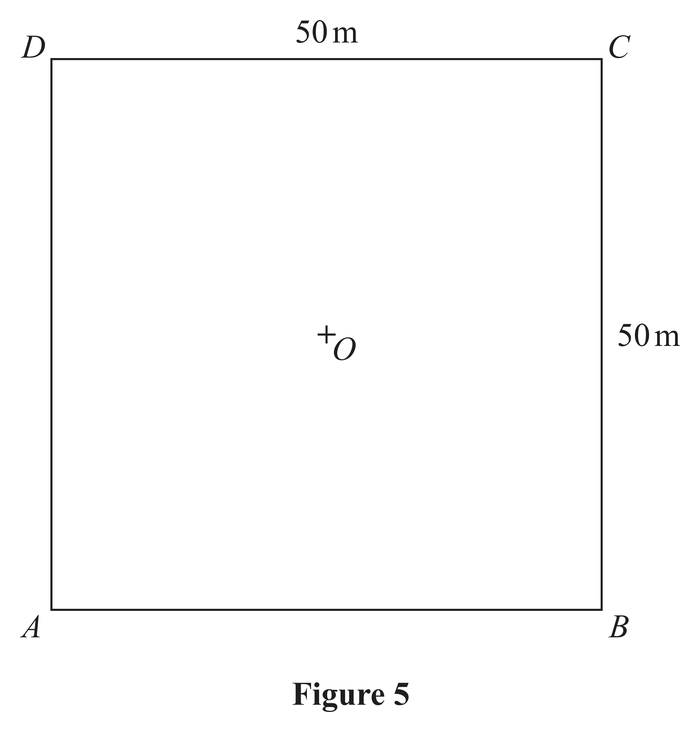
A square floor space ABCD, with centre O, is modelled as a flat horizontal surface measuring 50m by 50m, as shown in Figure 5.
The horizontal unit vectors i and j are in the direction of AB and AD respectively.
All position vectors are given relative to O.
A small robot R is programmed to travel across the floor at a constant velocity.
- At time t=0, R is at the point with position vector (−2i+j)m.
- At time t=11s, R is at the point with position vector (9i+23j)m.
- At time t seconds, the position vector of R is r metres.
(a) Find, in terms of t, i and j, an expression for r.
(3)
A second robot S is at the point C.
- At time t=0, S leaves C and moves with constant velocity (−i−j)ms−1.
- At time t seconds, the position vector of S is s metres.
(b) Write down, in terms of t, i and j, an expression for s.
(1)
(c) Show that
SR=[(2t−27)i+(3t−24)j]m
(2)
(d) Find the time when the distance between R and S is a minimum.
(3)
题目中文翻译
如图 5 所示,将以 O 为中心的正方形地面区域 ABCD 视为一个 50m 乘 50m 的平坦水平面。
水平单位向量 i 和 j 分别沿 AB 和 AD 的方向。
所有位置向量均相对于 O 给出。
一个小机器人 R 被编程为以恒定速度穿过该地面区域。
- 在 t=0 时,R 的位置向量为 (−2i+j)m。
- 在 t=11s 时,R 的位置向量为 (9i+23j)m。
- 在 t 秒时,R 的位置向量为 r 米。
(a) 求用 t、i 和 j 表示 r 的表达式。
(3)
第二个机器人 S 位于 C 点。
- 在 t=0 时,S 离开 C,以恒定速度 (−i−j)ms−1 运动。
- 在 t 秒时,S 的位置向量为 s 米。
(b) 写出用 t、i 和 j 表示 s 的表达式。
(1)
(c) 证明
SR=[(2t−27)i+(3t−24)j]m
(2)
(d) 求 R 与 S 之间的距离最小时的时刻。
(3)
解答
(a)
解法一
思路
展开
匀速运动的速度等于位移向量除以时间,再加回初始位置,得到任意时刻的位置向量。
答题过程
展开
The velocity of R is
vR=11(9i+23j)−(−2i+j)=i+2j ms−1.
Hence
r=(−2i+j)+t(i+2j)=(t−2)i+(2t+1)j m.
(b)
解法一
思路
展开
原点在正方形中心,右上角 C 的坐标是 (25,25)。把给定速度乘时间后加到这个初始位置。
答题过程
展开
Since OC=25i+25j m,
s=(25−t)i+(25−t)j m.
(c)
解法一
思路
展开
从 S 指向 R 的向量是 R 的位置减去 S 的位置,逐分量相减即可。
答题过程
展开
Using SR=r−s,
SR==[(t−2)−(25−t)]i+[(2t+1)−(25−t)]j,[(2t−27)i+(3t−24)j] m,
as required.
(d)
解法一
思路
展开
距离与距离平方在同一时刻最小。对距离平方配方,平方项为零时取得全局最小;再检查此时机器人仍在正方形内。
答题过程
展开
Let D be the distance between the robots. Then
D2===(2t−27)2+(3t−24)2,13t2−252t+1305,13(t−13126)2+131089.
The square is non-negative, so the minimum occurs at
t=13126 s≈9.69 s.
At this time,
r=13100i+13265j,s=13199i+13199j.
All coordinates lie between −25 and 25, so both robots are still on the floor.
解法二
思路
展开
也可对距离平方微分,解驻点,并以正的二阶导数证明是最小值。
答题过程
展开
The squared distance is
f(t)=(2t−27)2+(3t−24)2=13t2−252t+1305.
Thus
f′(t)=26t−252,f′′(t)=26>0.
The unique global minimum is at
26t−252=0,t=13126 s.
This is a non-negative time before R reaches the upper boundary at t=12 s and before S reaches the opposite corner at t=50 s.
